 matlabbe
ee49beaf4f
* added doc and tests for util2d.h

* updated cmake-ros ci

* Added util3d.h doc and tests

* util3d_transforms.h: Added doc and tests

* util3d_filtering.h: started doc and test

* util3d_filtering.h: more tests and doc

* Added more doc/tests

* finished util3d_filtering doc and tests

* added test for util2d::depthBleedingFiltering

* Added util3d_registration tests

* Added util3d_features.h doc/tests

* added doc/tests for util3d_correspondences.h

* added doc/gtest for util3d_mapping.h (missing hpp functions)

* finished testing util3d_mapping.hpp

* Added util3d_motion_estimation.h tests (2D->3D done)

* finished util3d_motion_estimation.h tests

* minimal util3d_surface.h

* Added Transform and VisualWord tests

* Added doc for CameraModel and StereoCameraModel

* Added more logs in ros ci

* Passing tests on fical

* improved all devcontainer

* added devcontainer kilted, fixed source setup.bash, removed ldconfig in ros-cmake workflow

* cleanup

* source ros

* Added utilite tests

* Added testing to appveyor, github actions cancellable on re-commit on same branch

* appveyor testing without all targets

* appveyor: specifying ALL_BUILD target

* Fixed Util2dTest.NMSImageBoundsRespected test

* Fixing PCL Indices error on old pcl

* Added VWDictionary tests and doc. Fixed LSH not working (fix from https://github.com/flann-lib/flann/pull/472

* fixing some appveyor CI errors, added test to check dictionary serialization against all type

* Added StereoDense, StereoBM and StereoSGBM doc and tests

* Added Stereo tests

* Added CameraModel and StereoCameraModel tests

* Added doc and test for Statistics

* Added doc/tests for Signature

* Added doc/test for SensorEvent, added doc for SensorCaptureInfo

* Added doc to SensorData

* Added SensorData tests

* Added SensorCapture and SensorCaptureThread doc and tests

* fixed sensordata test

* updated SSC test and doc

* Added doc and tests for BayesFilter class

* Enabled testing on mac, updated windows testing like on linux

* added test_link

* fixed unresolved on windows

* fixed ThreadHandle error on macos ci

* Added GPS and GeodeticCoords tests

* Added tests for compression

* Added Odometry tests (base class only)

* Added DBDriver tests

* Added coverage report

* uniformized test names

* fixing concurancy and coverage ci

* dont built tools, examples and app for coverage build

* fixed report tool rebuilt without qt compilation error

* updated coverage option

* updated coverage config

* added doc CI job

* fixing windows and mac ci errors

* Added DBDriverSqlite3 tests

* Added IMU tests

* Added Graph tests

* fixing flaky macos test

* Added IMUThread and IMUFilter tests

* Added Landmarks tests

* Added LASWriter tests

* fixing seed flaky test

* fixing flaky macos timing tests

* Added LocalGrid tests

* Added LocalGridMaker tests

* fixing ci errors

* Added GlobalMap tests

* Added doc for EnvSensor

* Added Features2D tests

* Added Registration tests

* Added RegistrationVis tests

* Added doc for Rtabmap and Memory classes

* Added Memory and Rtabmap tests

* making some tests less flaky

* lcov 1.14 support

* updated compatible tool arguments

* Added integration tests (RGB-D, Stereo, Lidar2d, Lidar3d)

* More octomap checks

* Refactored how/when python interpretor is created to simplify library usage

* Added python tests

* fixed some flaky tests

* suppressed some third party related warnings

* fixed ceres tests

* more flaky fixes

* Fixing tests without libpointmatcher

* Added RANSAC rejection filter to PCL ICP

* fixing multi platform flakiness

* Added test to detect regression

* Fixing windows pcl link error

* fixed some macos flakiness

* bigger 2D2D registration error on opencv 4.6.0

* flakiness

* fixing flaky tests on windows and mac

* flaky thread test on slow mac VM

* windows slow test

* fixing more ci erros

* fxing temp dir on windows

* Added Optimizer tests and discovered some bugs (fixed)

* fixing flaky tests in mac and windows

* Added Optimizer doc

* Added GTSAM BA, updated Ceres to use g2o ba parameters. Renamed g2o's ba related parameters to Optimizer group and used by both gtsam and ceres.

* fixing build without gtsam

* fixing home dir

* fixing python ci isssues

* Added multicam ba tests

* Added Ceres multicam BA support

* Aligned BundleAdjustment parameters with Optimizer/Strategy to avoid confusion in the code

* Added BA integration test

* Added robust graph optimization integration test

* Added loop3it test

* Added stereo20Hz test

* Added smartfactor gtsam

* Fixed bugged check and warn if python didn't return any descriptors

* Fixing gtsam version build issues

* fixing tilt on windows ci

* loosing ceres integration test for ci

* mac ci flakiness

* updating missing param in gui

* updating test bound for mac

* added appearance-based tests, set min gftt quality to quality level

* testing more stuff

* improving features2d tests

* ci flakiness

* fixing flaky ci

* ci fixes

* flaky fixes

* Added RegistrationIcp tests

* Added icp integration test with real-worl corridor like env

* intermediate nodes

* fixing enum

* Updated test to catch #1714

* Fixed 2d corridor failing on pcl

* flaky pnp test

* flaky brisk test

* Set rtabmap_integration test as long

* updating loop closure test

* flaky ci tests

* TEsting roundtrip g2o/toro save/load

* loosing test bound

* fixed cuda capable checks

* flaky tests

* Debugging test hanging

* more debugging stuff

* updating limit

* windows: disabled cuda on ci to avoid incompatible driver issue. Fixing a bad test mem allocation

* trying fixing cuda hanging issue

* fixing ci flakyness

* flaky tests

* Updated BOW flaky tests by checking min precision/recall instead of recall@100precision. Fixed signature test

* CameraModel::load() test initRectificationMap param

* test dbdriver load dictionary idsOnly

* Memory: test keepLinkedInDb param

* added dummyDictionary tests

* test intermediate nodes count

* Added MarkerDetector tests

* reverted breaking change of UMutex and USemaphore

* Features2d: fixed compiltion warnings with clang about override

* clang warnings

* fixing test build with pcl 1.8

* g2o and gtsam build errors on android

* opencv5 test fixes

* disabled testing for ios and android builds

* normalized endline characters for easier diff

* added LF CRLF rule

* bump 0.23.10. fixing doc version

* Publish rtabmap website doc from ci

* fixing MSCVC build error

* macos icp flaky test

* fixing ceres macos test bound

* ficing more flaky tests

* fixing opencv5 related test errors. Also fixed an actual bug in ENU_WGS84ToGeocentric_WGS84()

* added comment about mrpt change

* removed rosdoc2 (will add it for rtabmap_ros later)

* fixing website style

* updated download links

* locally deployable website with api

* sweep doxygen issues

* improved/revised doxygen main pages

* removed examples empty page

* Updated doxygen style

* more concise doxygen groups

* added api link on main readme

* fixing utilite test error

* fixing CommonFilteringGroundNormalsUp test

* updated precisionRecall test bounds for Freak and brief descriptors

* fixing scale check in ba tests

* disabled tests on windows cuda build (missing dlls amd runner cannot test cuda anyway)

* ceres: missing suitesparse dep in windows ci

* adjusting recall thr for fast/freak

* ficing more flaky tests

* fixing flaky tests

* disabled coverage in ros ci

* Enable integration tests for ros ci jobs

* loosing up some threshold for failing tests

* trigger cache

* fixing test data in ros ci. Updated flaky test for mac

* slaking some test limit

* Fixed rtabmap-detectMoreLoopClosures inverted output value

* loosing up sift recall on mac

* optimizer re-ordered distribution for reproducible results (mac g2o)

* macos dump test crash log

* combining all tests to save time on shared library reload. Also fixed Logs with missing arguments.

* Added ENABLE_FORMAT_ERRORS cmake option

* do test only one time

* fixed all format warnings

* format security android build errors

* less verbose tests

* updated ImuUThread test

* fixed a log

* Fixed libpointmatcher 2d normals eigen issue

* Fixing libpointmatcher conversion issues

* fixing libpointmatcher test on windows ci

* cleanup comments, relax some test thr

* disabled sequoia-intel ci build (too flaky, would need extensive testing directly on that machine)
24 KiB
Overview
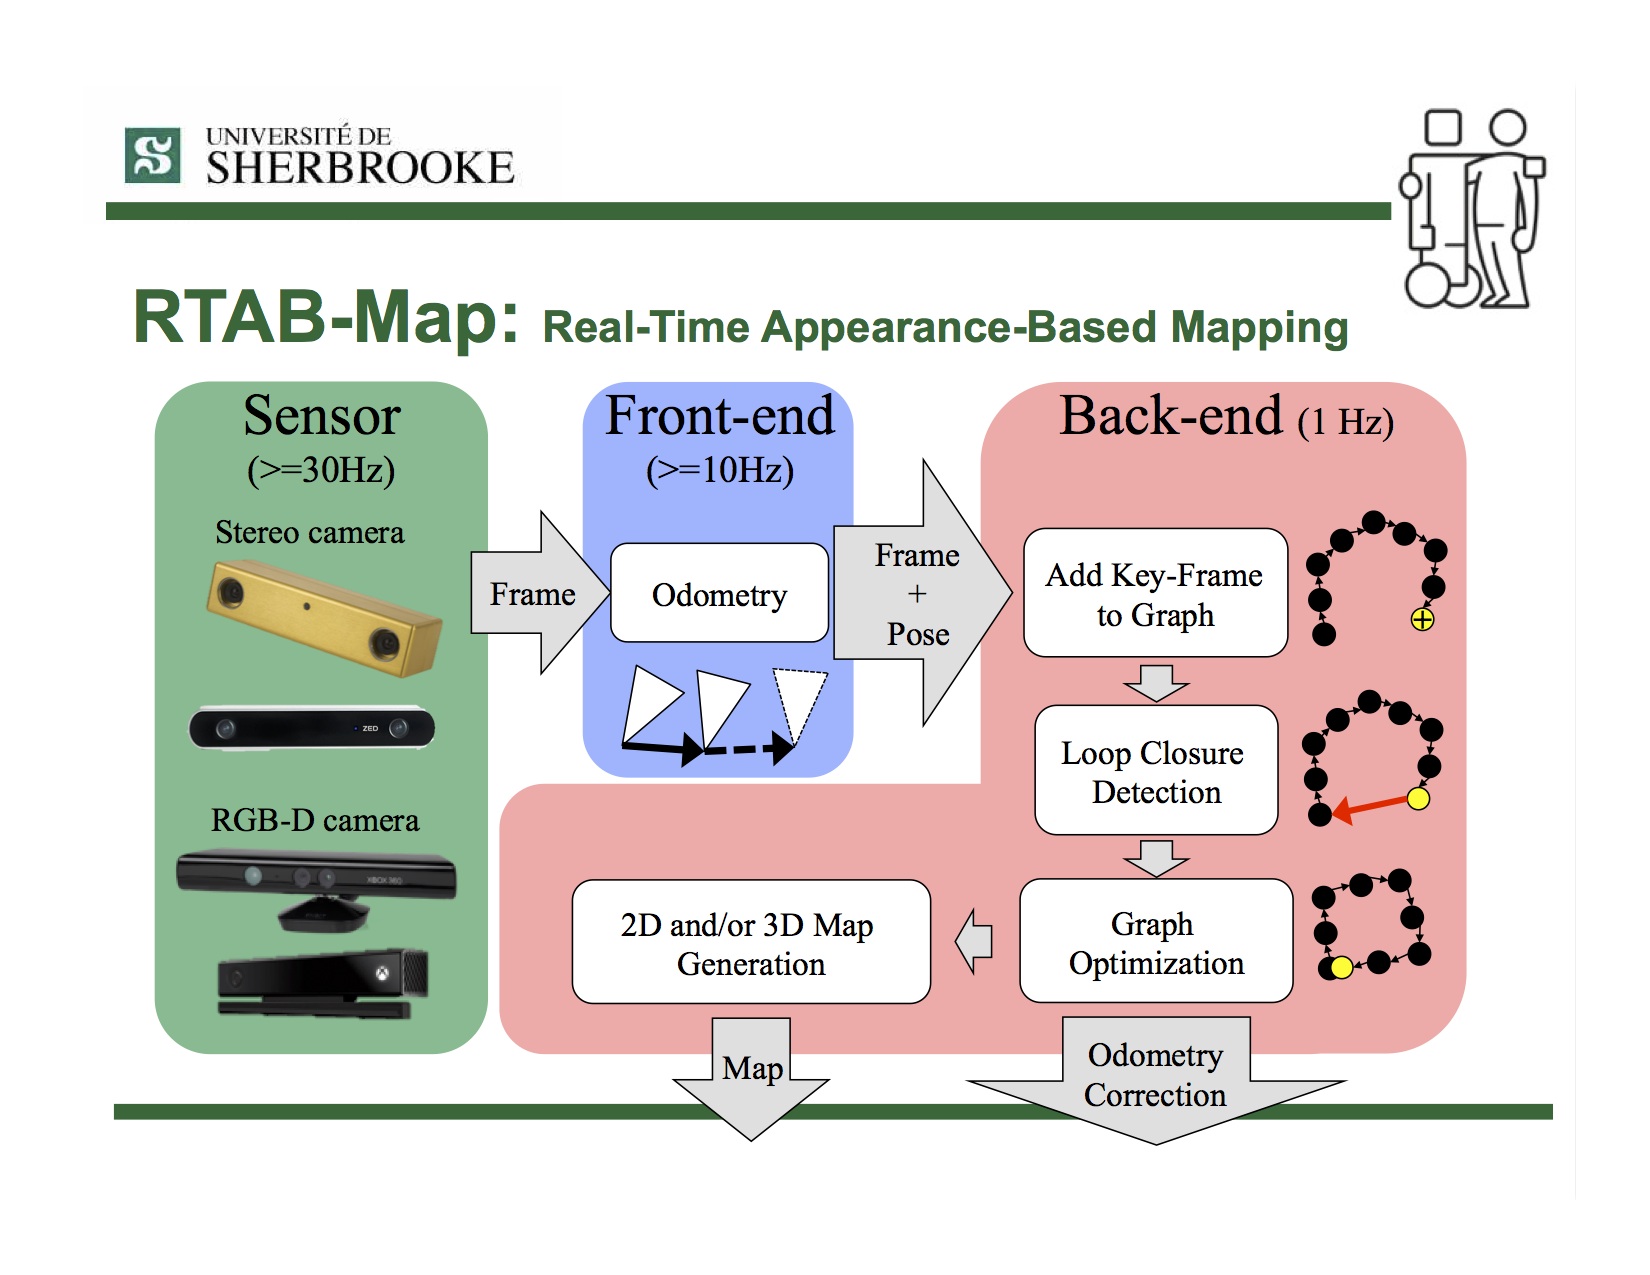
RTAB-Map (Real-Time Appearance-Based Mapping) is a RGB-D, Stereo and Lidar Graph-Based SLAM approach based on an incremental appearance-based loop closure detector. The loop closure detector uses a bag-of-words approach to determinate how likely a new image comes from a previous location or a new location. When a loop closure hypothesis is accepted, a new constraint is added to the map's graph, then a graph optimizer minimizes the errors in the map. A memory management approach is used to limit the number of locations used for loop closure detection and graph optimization, so that real-time constraints on large-scale environnements are always respected. RTAB-Map can be used alone with a handheld Kinect, a stereo camera or a 3D lidar for 6DoF mapping, or on a robot equipped with a laser rangefinder for 3DoF mapping.
Illumination-Invariant Visual Re-Localization
- M. Labbé and F. Michaud, “Multi-Session Visual SLAM for Illumination-Invariant Re-Localization in Indoor Environments,” in Frontiers in Robotics and AI, vol. 9, 2022. (Frontiers) (Dataset link) (Google Scholar)
Lidar and Visual SLAM
- M. Labbé and F. Michaud, “RTAB-Map as an Open-Source Lidar and Visual SLAM Library for Large-Scale and Long-Term Online Operation,” in Journal of Field Robotics, vol. 36, no. 2, pp. 416–446, 2019. (Wiley) (Google Scholar)
Simultaneous Planning, Localization and Mapping (SPLAM)
- M. Labbé and F. Michaud, “Long-term online multi-session graph-based SPLAM with memory management,” in Autonomous Robots, vol. 42, no. 6, pp. 1133-1150, 2018. (Springer) (Google Scholar)
Multi-session SLAM
- M. Labbé and F. Michaud, “Online Global Loop Closure Detection for Large-Scale Multi-Session Graph-Based SLAM,” in Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems, 2014. (IEEE Xplore) (Google Scholar)
- Results shown in this paper can be reproduced by the Multi-session mapping tutorial.
Loop closure detection
- M. Labbé and F. Michaud, “Appearance-Based Loop Closure Detection for Online Large-Scale and Long-Term Operation,” in IEEE Transactions on Robotics, vol. 29, no. 3, pp. 734-745, 2013. (IEEE Xplore) (Google Scholar)
- M. Labbé and F. Michaud, “Memory management for real-time appearance-based loop closure detection,” in Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems, 2011, pp. 1271–1276. (IEEE Xplore) (Google Scholar)
- Visit RTAB-Map's page on IntRoLab for detailed information on the loop closure detection approach and related datasets.
- Visit this page for usage example of the CLI tool that van be used to evaluate only RTAB-Map's loop closure detector on new datasets.
Install


- Installation instructions.
- Tutorials.
- Tools.
- [C++ API documentation]({{ site.baseurl }}/api/) of the rtabmap library.
- For ROS users, take a look to rtabmap page on the ROS wiki for a package overview. See also SetupOnYourRobot to know how to integrate RTAB-Map on your robot.
Troubleshooting
Standalone
- Visit the wiki.
- Ask a question on RTAB-Map Forum (New address! August 9, 2021).
- Post an issue on GitHub
- For the loop closure detection approach, visit RTAB-Map on IntRoLab website
- Enabled Github Discussions (New! November 2022)
ROS
- Visit rtabmap_ros wiki page for nodes documentation, demos and tutorials on ROS.
- Ask a question on
answers.ros.orgrobotics.stackexchange.com with rtabmap or rtabmap-ros tag.
License
- If OpenCV is built without the nonfree module, RTAB-Map can be used under the permissive BSD License.
- If OpenCV is built with the nonfree module, RTAB-Map is free for research only because it depends on SURF features. SURF is not free for commercial use. Note that SIFT patent has expired, so it can be a good free equivalent of SURF.
- SURF noncommercial notice: http://www.vision.ee.ethz.ch/~surf/download.html
Privacy Policy
RTAB-Map App on Google Play Store or Apple Store requires access to camera to record images that will be used for creating the map. When saving, a database containing these images is created. That database is saved locally on the device (on the sd-card under RTAB-Map folder). While location permission is required to install RTAB-Map Tango, the GPS coordinates are not saved by default, the option "Settings->Mapping...->Save GPS" should be enabled first. RTAB-Map requires read/write access to RTAB-Map folder only, to save, export and open maps. RTAB-Map doesn't access any other information outside the RTAB-Map folder. RTAB-Map doesn't share information over Internet unless the user explicitly exports a map to Sketchfab or anywhere else, for which RTAB-Map needs the network. If so, the user will be asked for authorization (oauth2) by Sketchfab (see their Privacy Policy here).
This website uses Google Analytics. See their Privacy Policy here.
Author
- Mathieu Labbé
- RTAB-Map's page at IntRoLab
- Papers
- Similar projects: Find-Object
What's new
December 2024
ROS2 packages overhaul (see ros2 branch): we added new ROS2 demos and examples. We also fixed message_filters related synchronization issues causing significant lags when using ROS2 nodes (in comparison to ROS1). Binaries ros-$ROS_DISTRO-rtabmap-ros will be released under version 0.21.9.
November 2023
We had new papers published this year on a very fun project about underground mines scanning. Here is a video of the SLAM part of the project realized with RTAB-Map (it is an early field test we did before going in the mines):
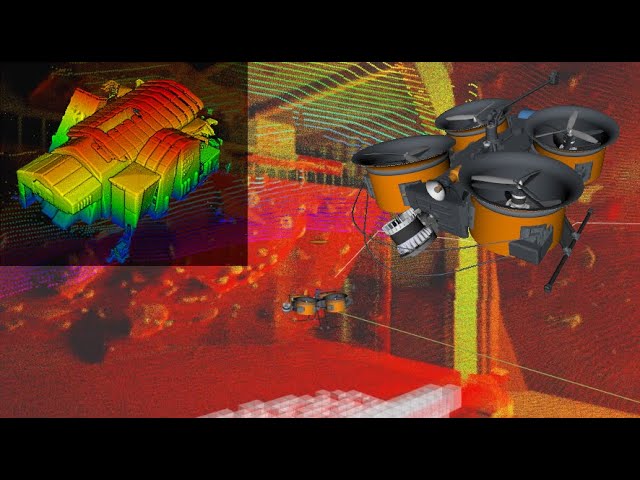
Related papers:
-
Leclerc, M.A., Bass, J., Labbé, M., Dozois, D., Delisle, J., Rancourt, D. and Lussier Desbiens, A., 2023. "NetherDrone: A tethered and ducted propulsion multirotor drone for complex underground mining stopes inspection". Drone Systems and Applications. (Canadian Science Publishing) (Editor's Choice)
-
Petit, L. and Desbiens, A.L., 2022. "Tape: Tether-aware path planning for autonomous exploration of unknown 3d cavities using a tangle-compatible tethered aerial robot". IEEE Robotics and Automation Letters, 7(4), pp.10550-10557. (IEEE Xplore)
March 2023
New release v0.21.0!
June 2022
A new paper has been published: Multi-Session Visual SLAM for Illumination-Invariant Re-Localization in Indoor Environments. The general idea is to remap multiple times the same environment to capture multiple illumination variations caused by natural and artificial lighting, then the robot would be able to localize afterwards at any hour of the day. For more details, see this page and the linked paper. Some great comparisons about robustness to illumination variations between binary descriptors (BRIEF/ORB, BRISK), float descriptors (SURF/SIFT/KAZE/DAISY) and learned descriptors (SuperPoint).

January 2022
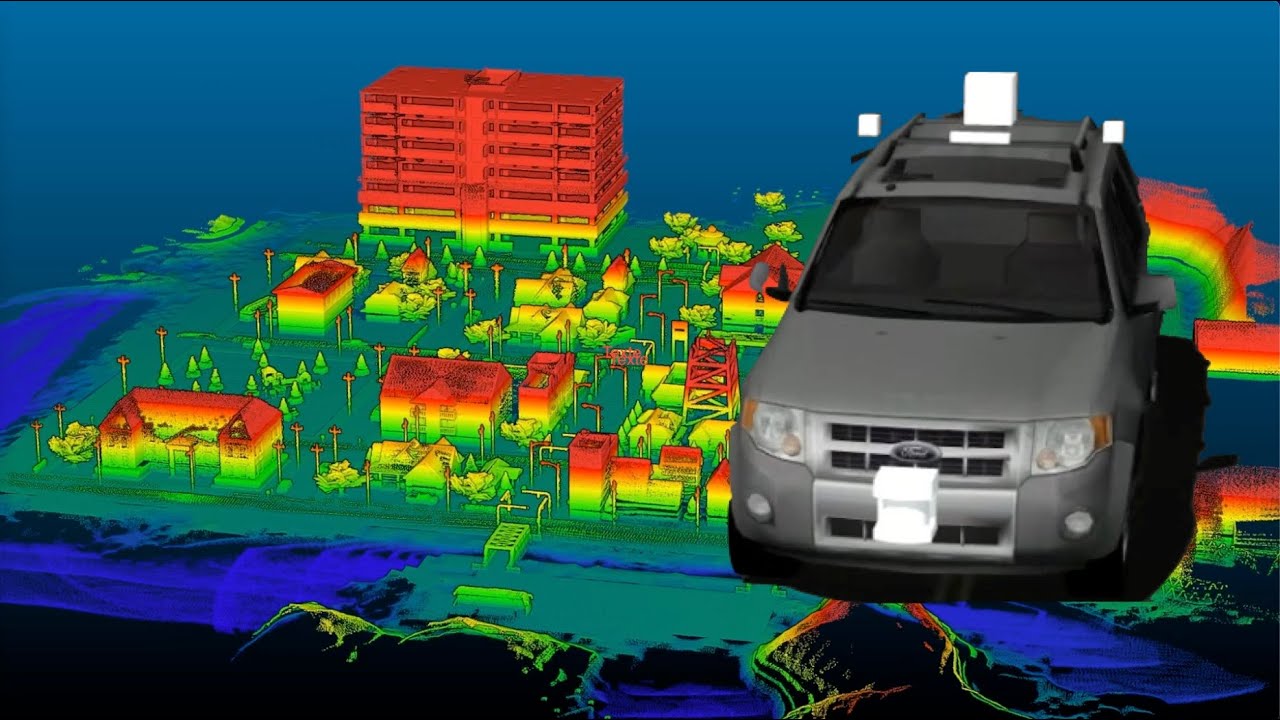
Added demo for car mapping and localization with CitySim simulator and CAT Vehicle:
December 2021
Added indoor drone visual navigation example using move_base, PX4 and mavros:
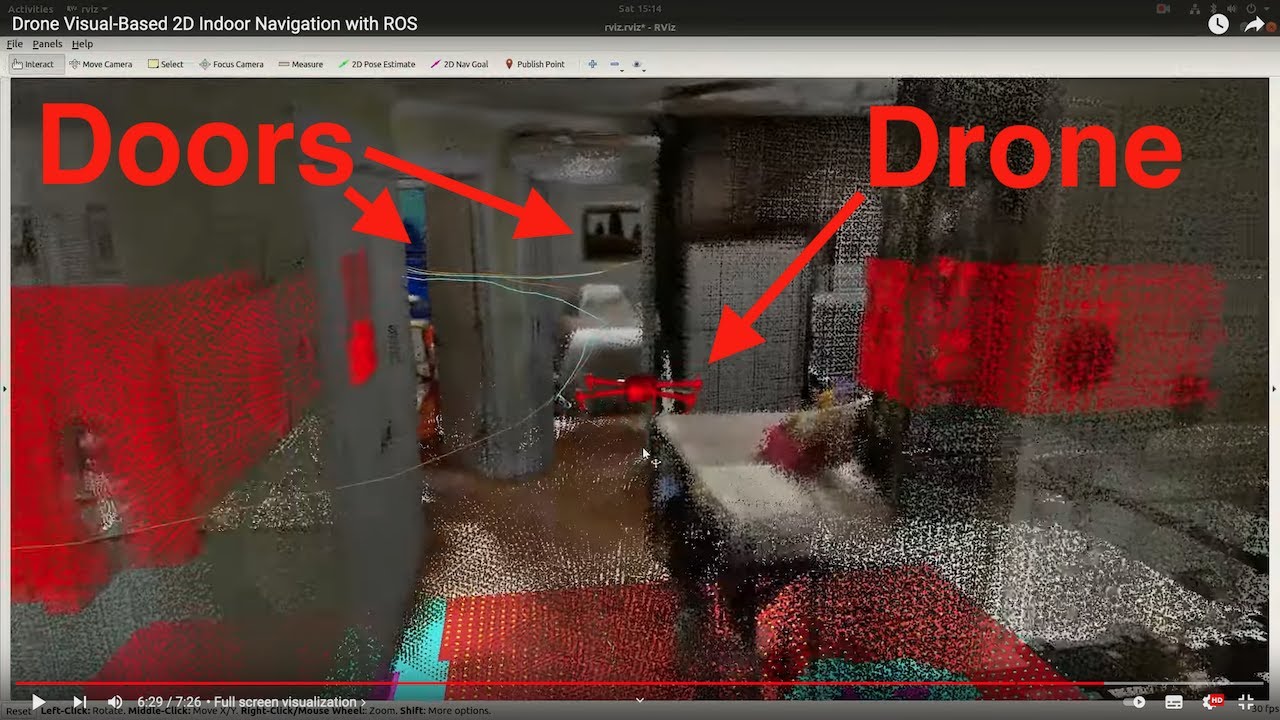
More info on the rtabmap-drone-example github repo.
June 2021
-
I'm pleased to announce that RTAB-Map is now on iOS (iPhone/iPad with LiDAR required). The app is available on App Store.
December 2020
New release v0.20.7!
August 2020
New release v0.20.3!
July 2020
New release v0.20.2!
November 2019
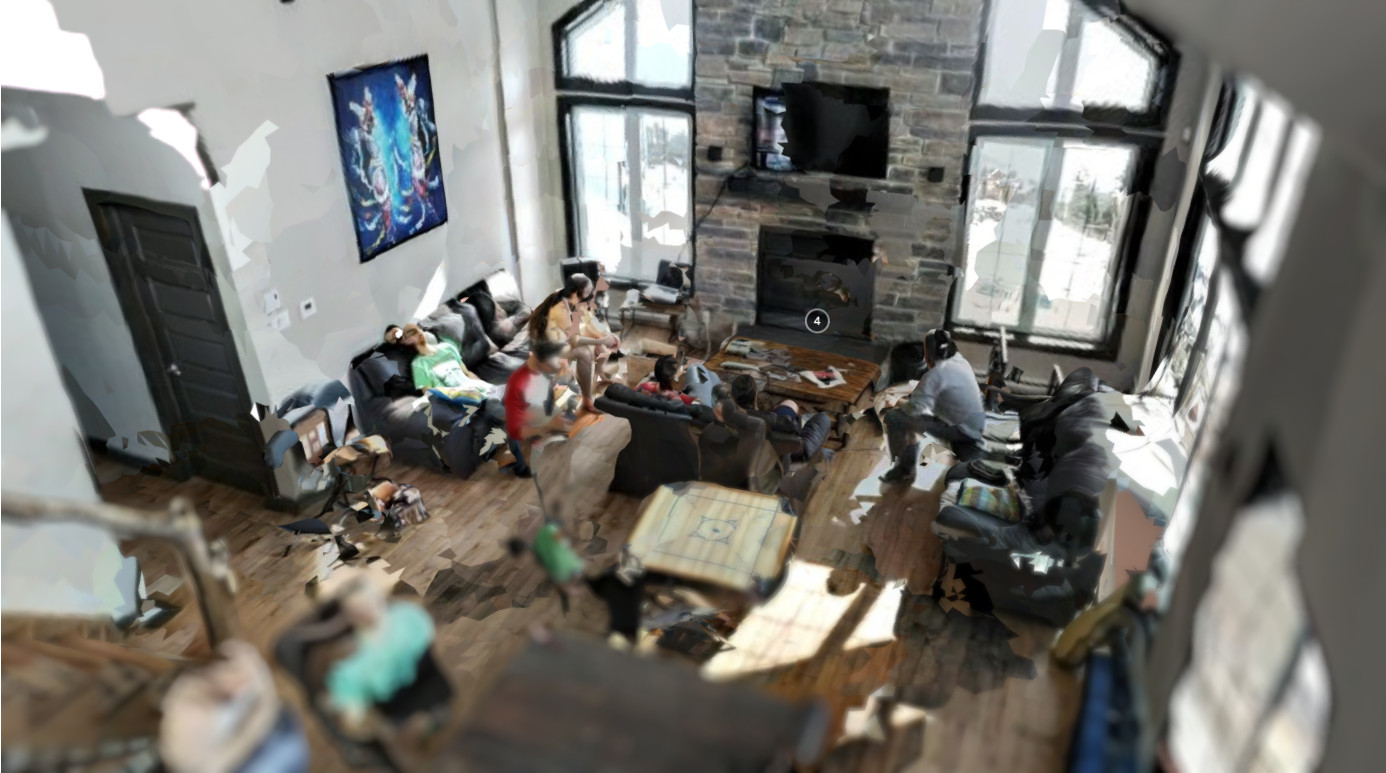
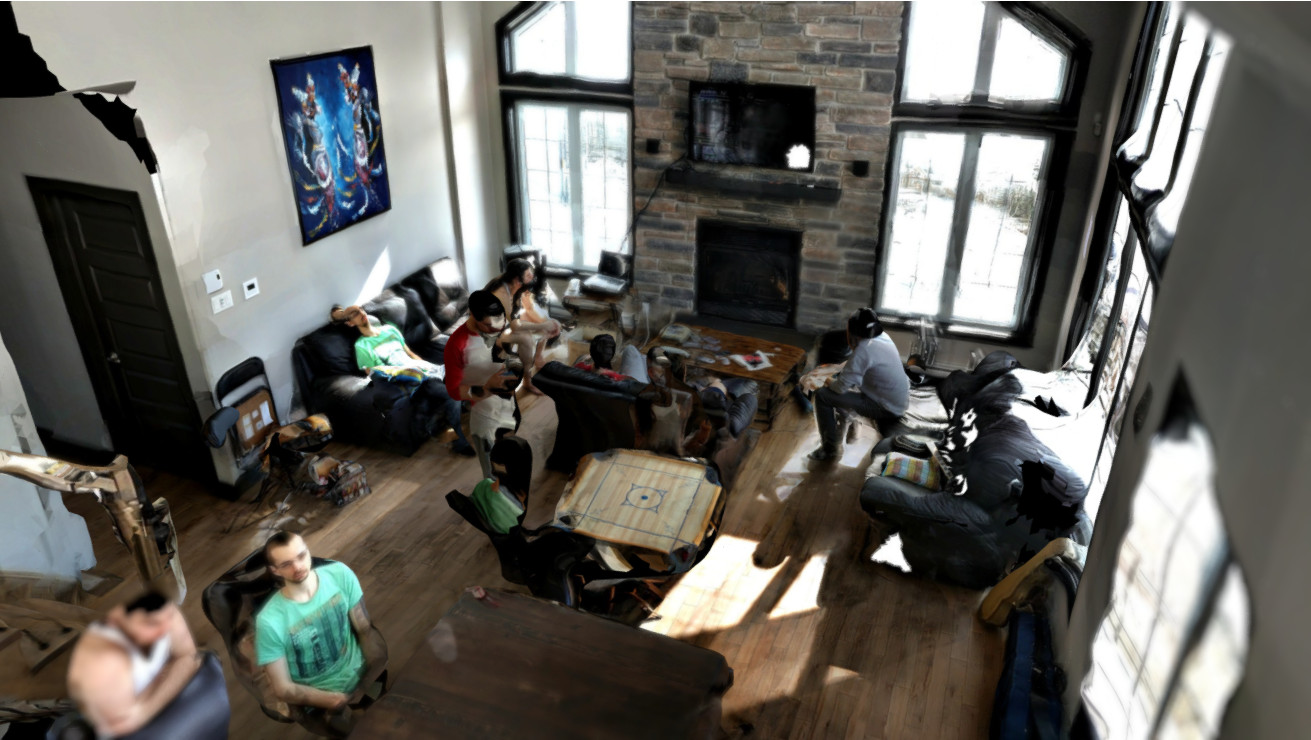
- AliceVision library has been integrated to RTAB-Map to provide higher texture quality. Compare the updated version of the Ski Cottage on Sketchfab with the old version. Look at how the edges between camera texures are smoother (thx to multi-band blending), decreasing significantly the sharp edge artifacts. Multi-band blending approach can be enabled in File->Export Clouds dialog under Texturing section. RTAB-Map should be built with AliceVision support (CUDA is not required as only texture pipeline is used). A patch is required to avoid problems with Eigen, refer to Docker file here.
September 2017
- New version 0.14 of RTAB-Map Tango with GPS support. See it on play store.
July 2017
-
New version 0.13 of RTAB-Map Tango. See it on play store.
-
I uploaded a presentation that I did in 2015 at Université Laval in Québec! A summary of RTAB-Map as a RGBD-SLAM approach:
March 2017
-
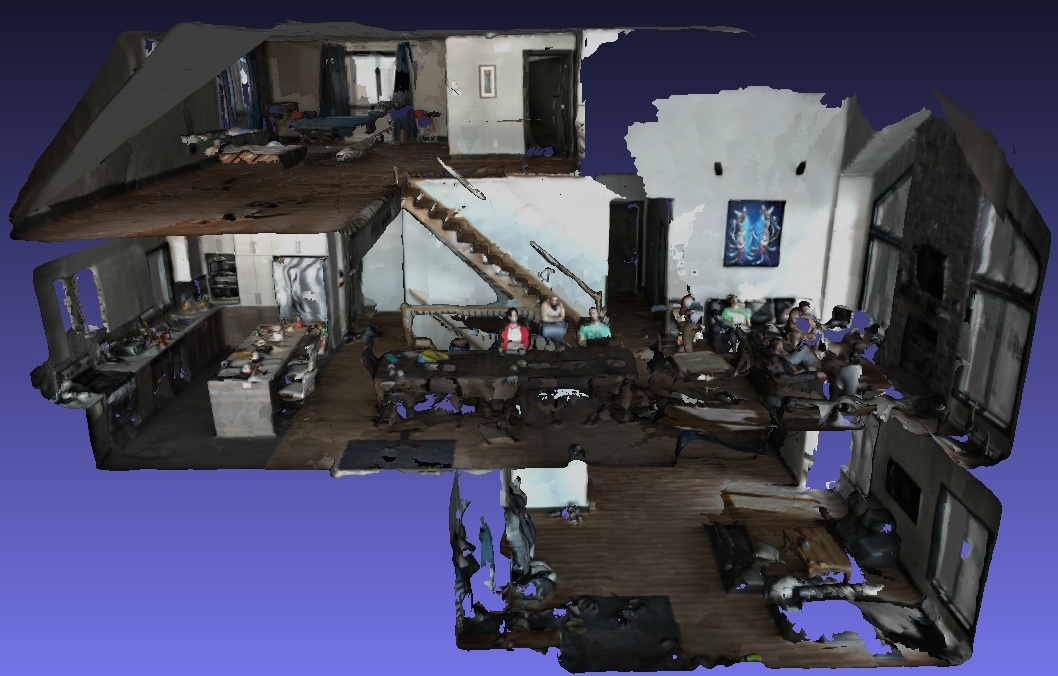
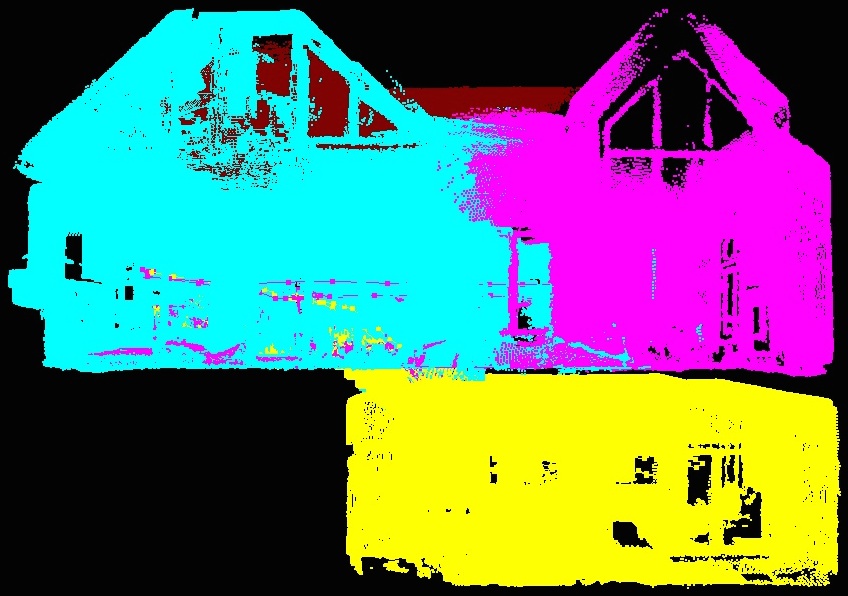
New tutorial: Multi-Session Mapping with RTAB-Map Tango
February 2017
-
Version 0.11.14 : Visit the release page for more info!
- Tango app also updated:
October 2016
-
Application example: See how RTAB-Map is helping nuclear dismantling with Orano's MANUELA project (Mobile Apparatus for Nuclear Expertise and Localisation Assistance):
-
Version 0.11.11: Visit the release page for more info!
July 2016
- Version 0.11.8: Visit the release page for more info!
June 2016
- Version 0.11.7: Visit the release page for more info!
February 2016
-
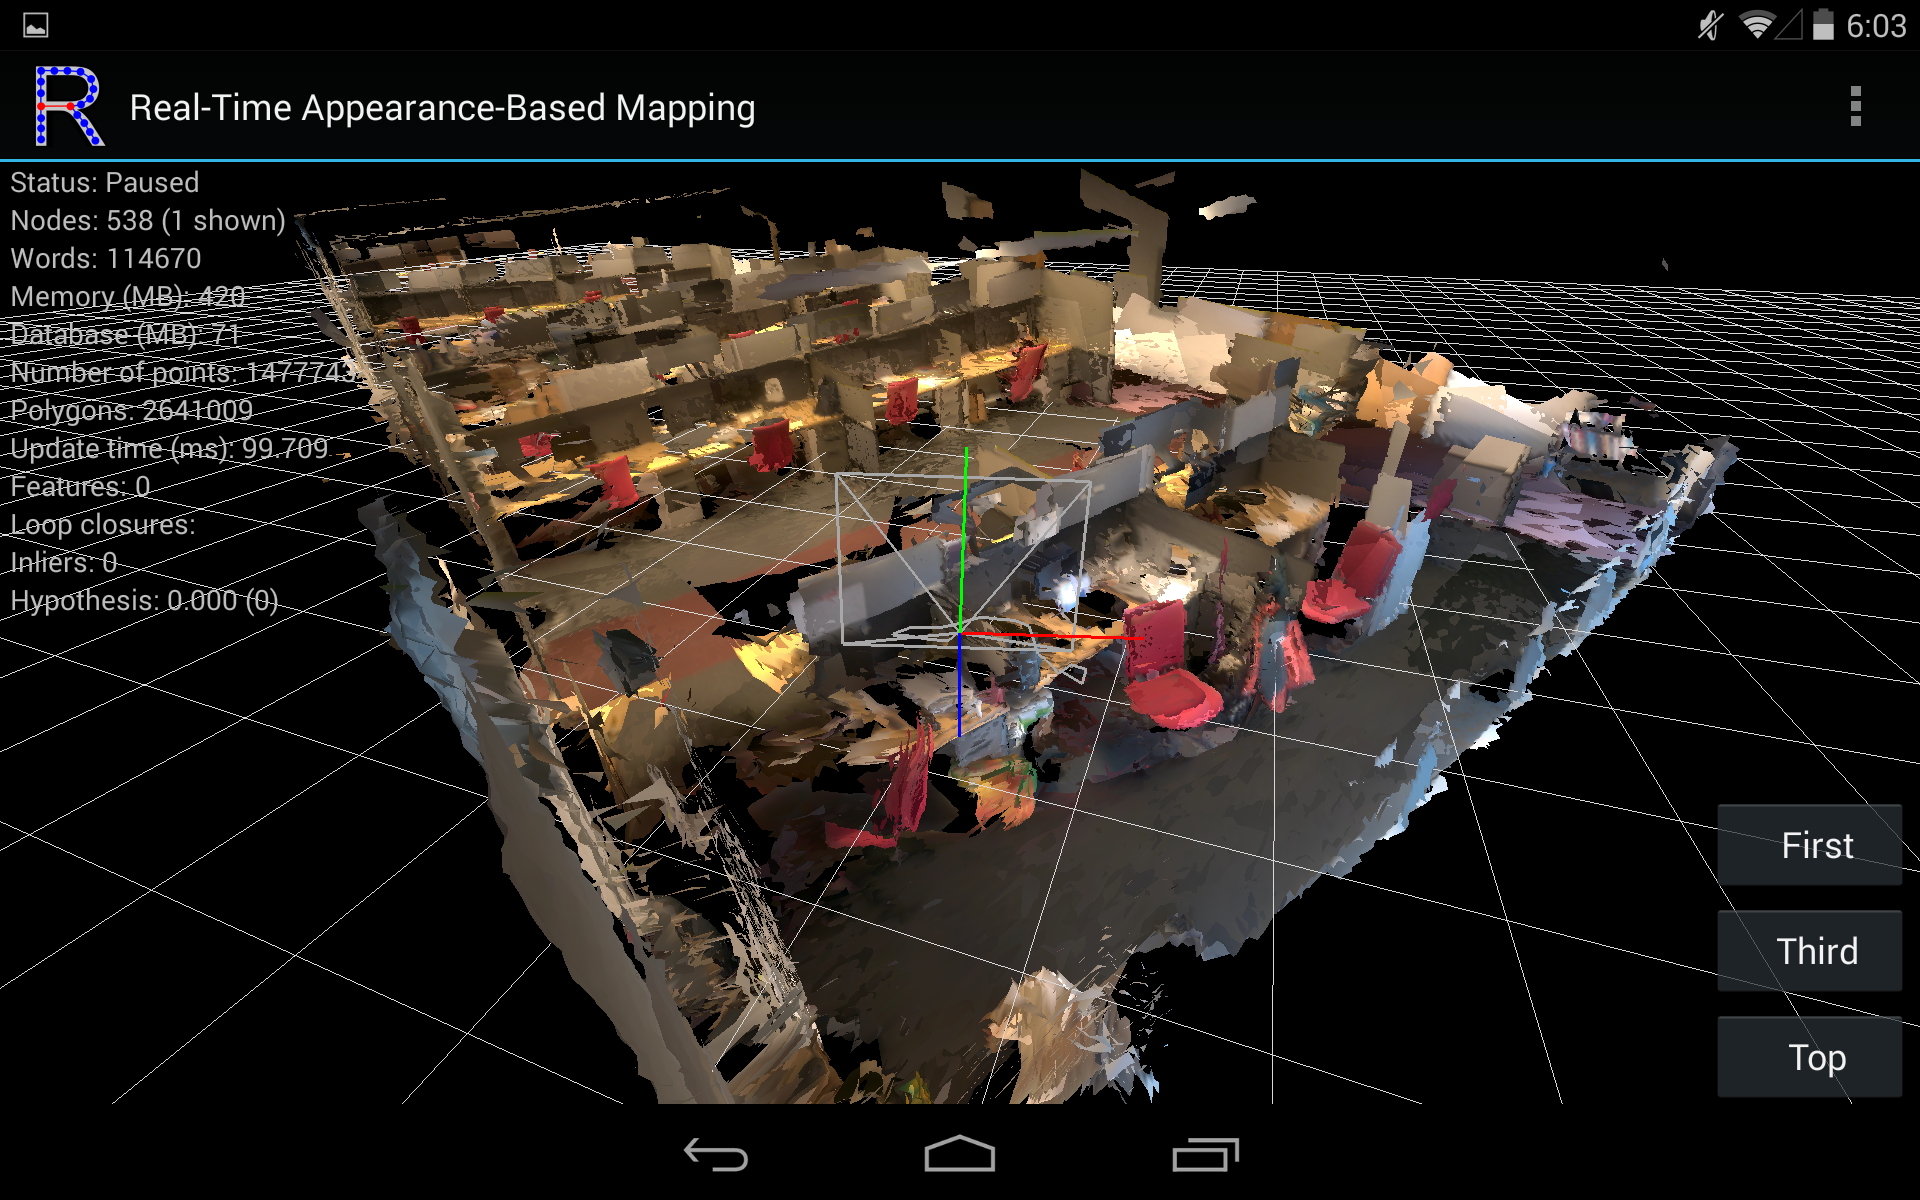
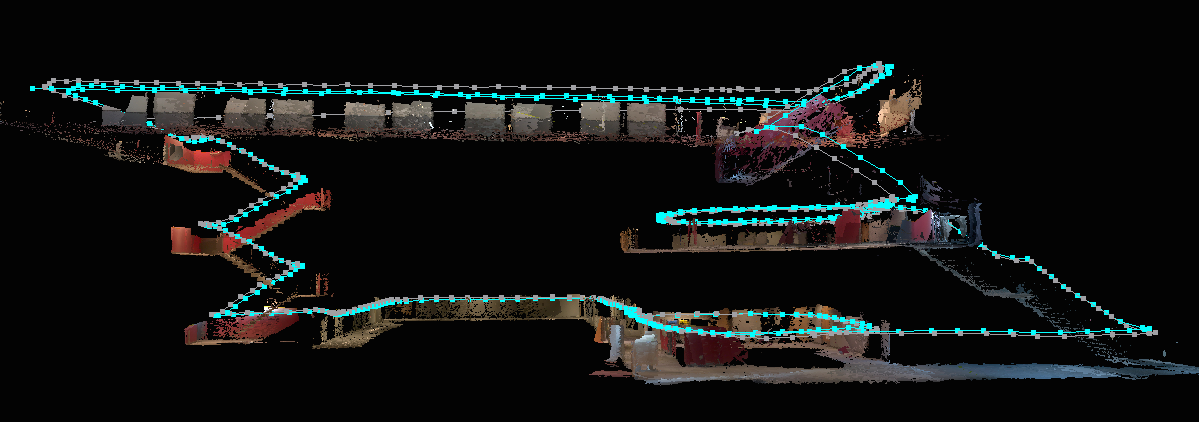
I'm pleased to announce that RTAB-Map is now on Project Tango. The app is available on Google Play Store.
- Screenshots:
October 2015
- Version 0.10.10: Visit the release page for more info!
September 2015
-
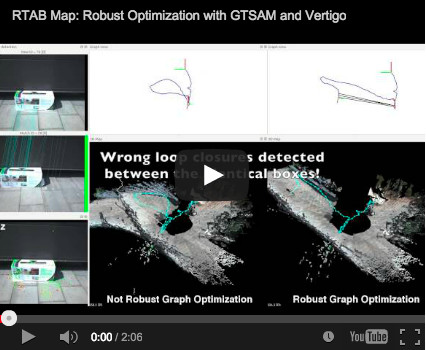
Version 0.10.6: Integration of a robust graph optimization approach called Vertigo (which uses g2o or GTSAM), see this page:
August 2015
-
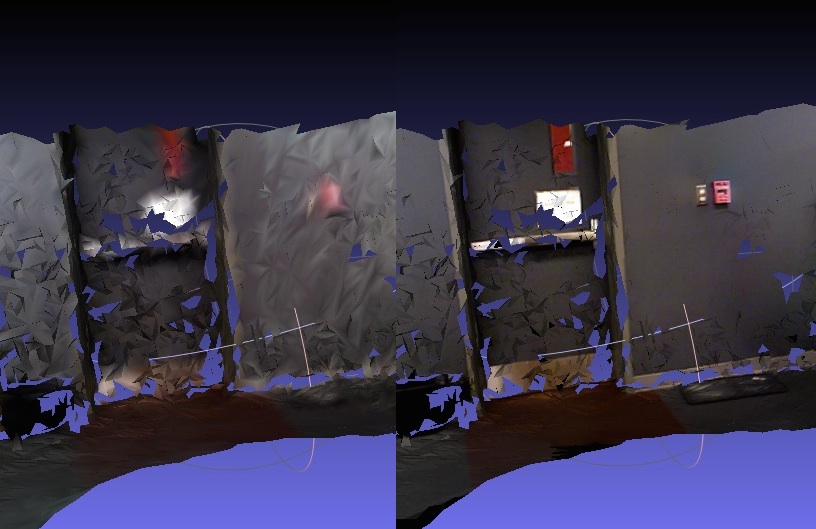
Version 0.10.5: New example to export data to MeshLab in order to add textures on a created mesh with low polygons, see this page:
October 2014
-
New example to speed up RTAB-Map's odometry, see this page:
September 2014
-
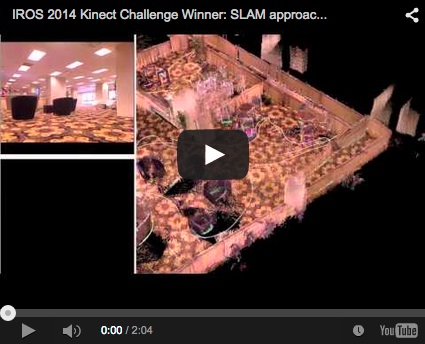
At IROS 2014 in Chicago, a team using RTAB-Map for SLAM won the Kinect navigation contest held during the conference. See their press release for more details: Winning the IROS2014 Microsoft Kinect Challenge. I also added the Wiki page IROS2014KinectChallenge showing in details the RTAB-Map part used in their solution.
August 2014
-
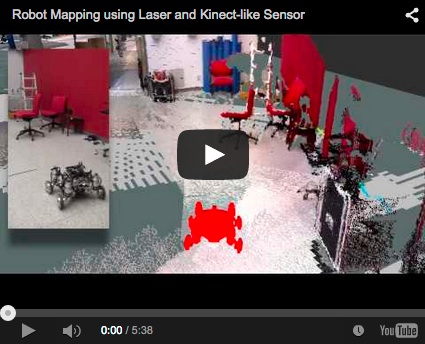
Here a comparison between reality and what can be shown in RVIZ (you can reproduce this demo here):
July 2014
-
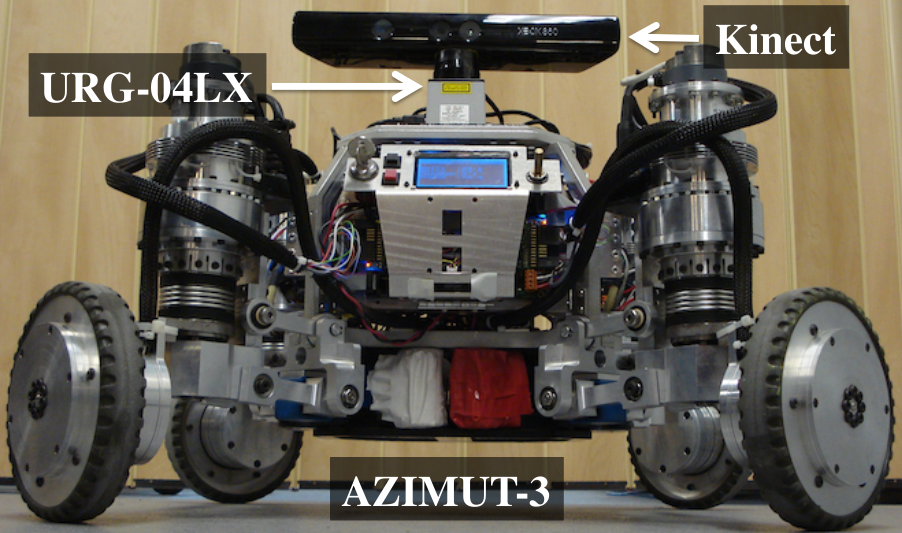
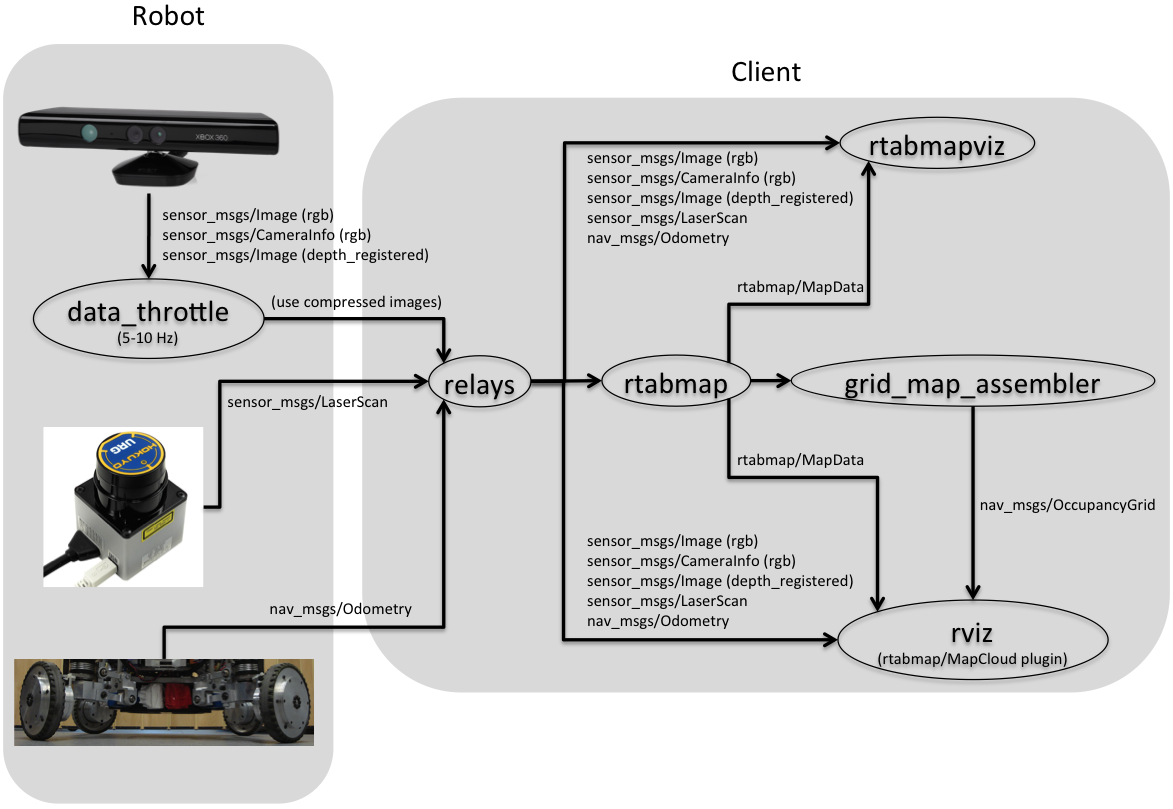
Added Setup on your robot wiki page to know how to integrate RTAB-Map on your ROS robot. Multiple sensor configurations are shown but the optimal configuration is to have a 2D laser, a Kinect-like sensor and odometry.
Onboard mapping Remote mapping 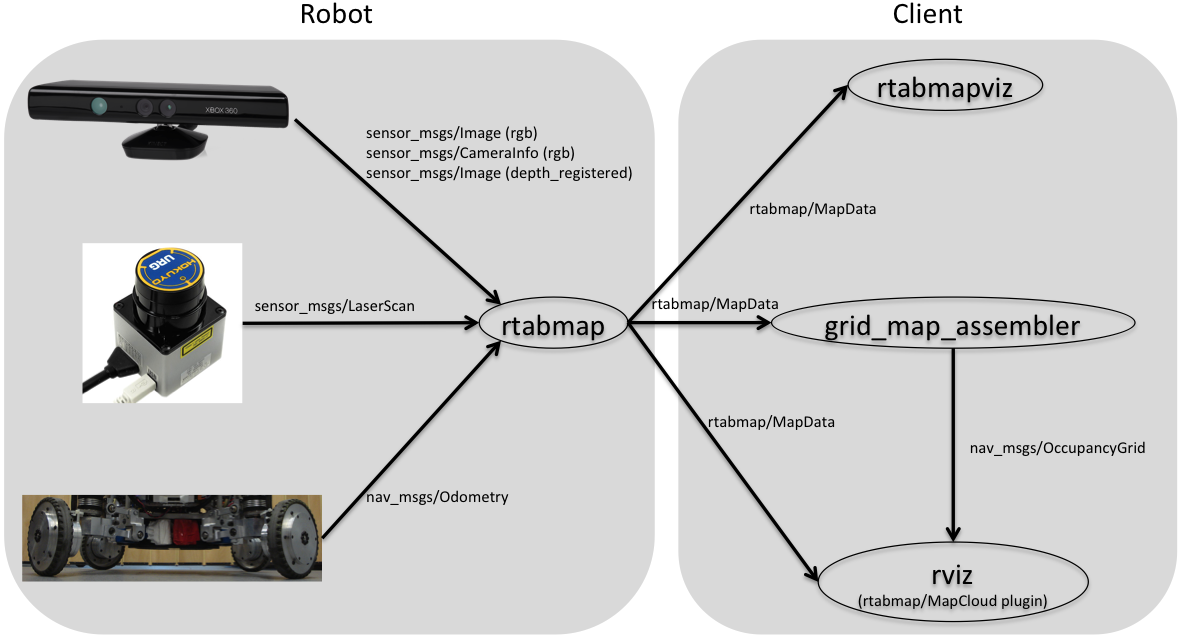
June 2014
-
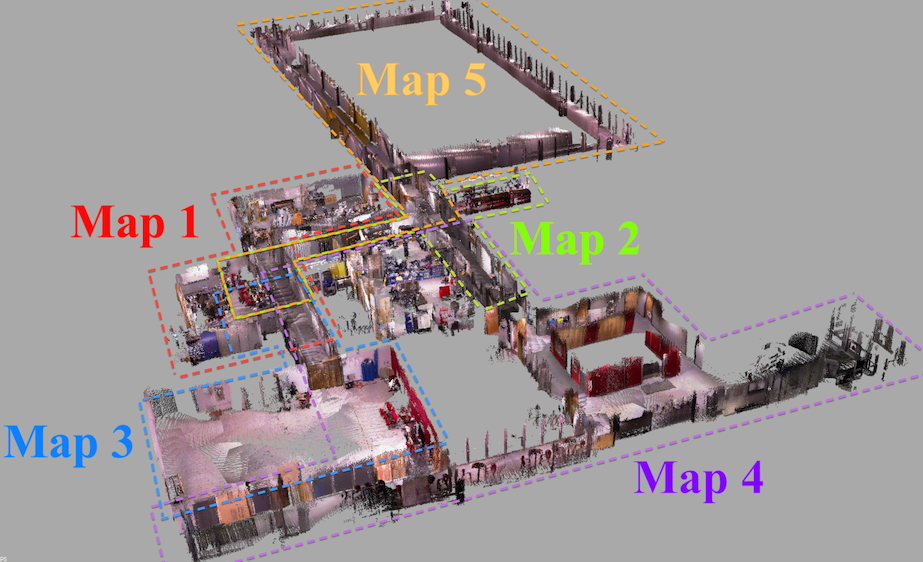
I'm glad to announce that my paper submitted to IROS 2014 was accepted! This paper explains in details how RGB-D mapping with RTAB-Map is done. Results shown in this paper can be reproduced by the Multi-session mapping tutorial:
Videos
-
RGBD-SLAM
-
Appearance-based loop closure detection
-
More loop closure detection videos here.