Sparse stereo matching using optical flow. More...
#include <Stereo.h>
Public Member Functions | |
| StereoOpticalFlow (const ParametersMap ¶meters=ParametersMap()) | |
| Constructor. | |
| virtual | ~StereoOpticalFlow () |
| Virtual destructor. | |
| virtual void | parseParameters (const ParametersMap ¶meters) |
| Parse parameters from a parameters map. | |
| virtual std::vector< cv::Point2f > | computeCorrespondences (const cv::Mat &leftImage, const cv::Mat &rightImage, const std::vector< cv::Point2f > &leftCorners, std::vector< unsigned char > &status) const |
| Compute stereo correspondences using optical flow. | |
| float | epsilon () const |
| Get the convergence threshold (epsilon) | |
| virtual bool | isGpuEnabled () const |
| Check if GPU acceleration is enabled. | |
| bool | usingMinEigenVals () const |
| float | minEigThreshold () const |
| float | errorThreshold () const |
 Public Member Functions inherited from rtabmap::Stereo | |
| Stereo (const ParametersMap ¶meters=ParametersMap()) | |
| Constructor. | |
| virtual | ~Stereo () |
| Virtual destructor. | |
| cv::Size | winSize () const |
| Get the search window size. | |
| int | iterations () const |
| Get the number of iterations. | |
| int | maxLevel () const |
| Get the maximum pyramid level. | |
| float | minDisparity () const |
| Get the minimum disparity value. | |
| float | maxDisparity () const |
| Get the maximum disparity value. | |
| bool | winSSD () const |
| Check if SSD (Sum of Squared Differences) is used. | |
Additional Inherited Members | |
| Static Public Member Functions inherited from rtabmap::Stereo | |
| static Stereo * | create (const ParametersMap ¶meters=ParametersMap()) |
| Factory method to create a Stereo instance. | |
Detailed Description
Sparse stereo matching using optical flow.
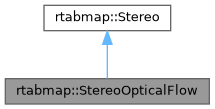
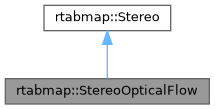
This class implements sparse stereo matching using optical flow (Lucas-Kanade) to find corresponding feature points between stereo image pairs. It extends the base Stereo class with optical flow-based matching, which can be more robust than simple block matching, especially for textured regions.
The algorithm uses pyramidal Lucas-Kanade optical flow to track feature points from the left image to the right image, then filters the results based on disparity constraints.
- Note
- Input images must be grayscale (CV_8UC1).
- GPU acceleration is available if RTAB-Map is built with OpenCV CUDA support.
- See also
- Stereo for block matching-based implementation
Constructor & Destructor Documentation
◆ StereoOpticalFlow()
| rtabmap::StereoOpticalFlow::StereoOpticalFlow | ( | const ParametersMap & | parameters = ParametersMap() | ) |
Constructor.
Initializes a StereoOpticalFlow instance with default parameter values and then parses the provided parameters map to override defaults.
- Parameters
-
parameters Optional parameters map containing configuration values. If empty, default values are used.
◆ ~StereoOpticalFlow()
|
inlinevirtual |
Member Function Documentation
◆ parseParameters()
|
virtual |
Parse parameters from a parameters map.
Updates the algorithm's configuration based on the provided parameters map. First calls the base class parseParameters(), then parses optical flow-specific parameters:
- Parameters::kStereoEps() - Convergence threshold for optical flow
- Parameters::kStereoGpu() - Enable GPU acceleration (requires OpenCV CUDA)
- Parameters
-
parameters Parameters map containing configuration values
- Note
- If GPU is enabled but RTAB-Map is not built with OpenCV CUDA support, GPU will be automatically disabled and an error message will be logged.
Reimplemented from rtabmap::Stereo.
◆ computeCorrespondences()
|
virtual |
Compute stereo correspondences using optical flow.
Finds corresponding points in the right stereo image for the given points in the left stereo image using pyramidal Lucas-Kanade optical flow. The results are filtered based on disparity constraints (minDisparity to maxDisparity).
- Parameters
-
leftImage Left stereo image (must be CV_8UC1 grayscale) rightImage Right stereo image (must be CV_8UC1 grayscale) leftCorners Input vector of feature points in the left image status Output vector indicating which correspondences are valid (1) or invalid (0). The size matches leftCorners.size().
- Returns
- Vector of corresponding points in the right image. The size matches leftCorners.size(). Invalid correspondences may have coordinates outside the image bounds.
- Note
- Both input images must be grayscale (CV_8UC1).
- If GPU is enabled, the GPU version of this method is called automatically.
Reimplemented from rtabmap::Stereo.
◆ epsilon()
|
inline |
◆ isGpuEnabled()
|
virtual |
Check if GPU acceleration is enabled.
Returns whether GPU acceleration is currently enabled for optical flow computation. GPU acceleration requires OpenCV CUDA support to be compiled in.
- Returns
- true if GPU is enabled and available, false otherwise
Reimplemented from rtabmap::Stereo.
◆ usingMinEigenVals()
|
inline |
◆ minEigThreshold()
|
inline |
◆ errorThreshold()
|
inline |
The documentation for this class was generated from the following file:
- corelib/include/rtabmap/core/Stereo.h