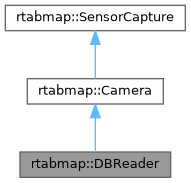
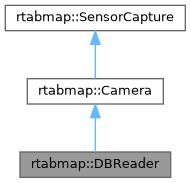
Public Member Functions | |
| DBReader (const std::string &databasePath, float frameRate=0.0f, bool odometryIgnored=false, bool ignoreGoalDelay=false, bool goalsIgnored=false, int startId=0, const std::vector< unsigned int > &cameraIndices=std::vector< unsigned int >(), int stopId=0, bool intermediateNodesIgnored=false, bool landmarksIgnored=false, bool featuresIgnored=false, int startMapId=0, int stopMapId=-1, bool priorsIgnored=false, bool imuIgnored=false, bool intermediateNodesAreNormalNodes=false, const std::vector< Transform > &cameraLocalTransformOverrides=std::vector< Transform >()) | |
| DBReader (const std::list< std::string > &databasePaths, float frameRate=0.0f, bool odometryIgnored=false, bool ignoreGoalDelay=false, bool goalsIgnored=false, int startId=0, const std::vector< unsigned int > &cameraIndices=std::vector< unsigned int >(), int stopId=0, bool intermediateNodesIgnored=false, bool landmarksIgnored=false, bool featuresIgnored=false, int startMapId=0, int stopMapId=-1, bool priorsIgnored=false, bool imuIgnored=false, bool intermediateNodesAreNormalNodes=false, const std::vector< Transform > &cameraLocalTransformOverrides=std::vector< Transform >()) | |
| virtual bool | init (const std::string &calibrationFolder=".", const std::string &cameraName="") |
| Initializes the sensor. | |
| virtual bool | isCalibrated () const |
| virtual std::string | getSerial () const |
| Returns the sensor's serial number or unique identifier. | |
| virtual bool | odomProvided () const |
| Checks if the sensor provides odometry poses. | |
| virtual bool | getPose (double stamp, Transform &pose, cv::Mat &covariance, double maxWaitTime=0.06) |
| Gets the sensor's pose estimate at a specific timestamp. | |
| const DBDriver * | driver () const |
 Public Member Functions inherited from rtabmap::Camera | |
| SensorData | takeImage (SensorCaptureInfo *info=0) |
| float | getImageRate () const |
| void | setImageRate (float imageRate) |
| void | setInterIMUPublishing (bool enabled, IMUFilter *filter=0, bool baseFrameConversion=false) |
| bool | isInterIMUPublishing () const |
| bool | initFromFile (const std::string &calibrationPath) |
| Public Member Functions inherited from rtabmap::SensorCapture | |
| virtual | ~SensorCapture () |
| Virtual destructor. | |
| SensorData | takeData (SensorCaptureInfo *info=0) |
| Captures sensor data with frame rate control. | |
| float | getFrameRate () const |
| Returns the target frame rate. | |
| const Transform & | getLocalTransform () const |
| Returns the local transform from base frame to sensor frame. | |
| void | setFrameRate (float frameRate) |
| Sets the target frame rate. | |
| void | setLocalTransform (const Transform &localTransform) |
| Sets the local transform from base frame to sensor frame. | |
| void | resetTimer () |
| Resets the frame rate timer. | |
Protected Member Functions | |
| virtual SensorData | captureImage (SensorCaptureInfo *info=0) |
| Protected Member Functions inherited from rtabmap::Camera | |
| Camera (float imageRate=0, const Transform &localTransform=Transform::getIdentity()) | |
| void | postInterIMU (const IMU &imu, double stamp) |
| Protected Member Functions inherited from rtabmap::SensorCapture | |
| SensorCapture (float frameRate=0, const Transform &localTransform=Transform::getIdentity()) | |
| Protected constructor. | |
| int | getNextSeqID () |
| Gets the next sequence ID. | |
Detailed Description
Definition at line 46 of file DBReader.h.
Member Function Documentation
◆ init()
|
virtual |
Initializes the sensor.
Pure virtual method that must be implemented by derived classes to initialize the sensor hardware or data source. This typically involves:
- Opening device connections or file streams
- Loading camera calibration parameters
- Configuring sensor settings
- Parameters
-
calibrationFolder Directory path where calibration files are located (default: current directory ".") cameraName Base name of the camera for loading calibration files (default: empty string)
- Returns
- True if initialization was successful, false otherwise
- Note
- Must be called before calling takeData() or captureData()
Implements rtabmap::SensorCapture.
◆ isCalibrated()
|
virtual |
Implements rtabmap::Camera.
◆ getSerial()
|
virtual |
Returns the sensor's serial number or unique identifier.
Pure virtual method that must be implemented by derived classes to return a unique identifier for the sensor (e.g., device serial number, file path, or other identifier).
- Returns
- String identifier for the sensor
Implements rtabmap::SensorCapture.
◆ odomProvided()
|
inlinevirtual |
Checks if the sensor provides odometry poses.
Some sensors (e.g., visual-inertial cameras) can provide pose estimates directly. This method indicates whether the sensor supports pose queries.
- Returns
- True if the sensor provides odometry poses, false otherwise
- Note
- Default implementation returns false. Derived classes should override if they support pose estimation.
- See also
- getPose()
Reimplemented from rtabmap::SensorCapture.
Definition at line 90 of file DBReader.h.
◆ getPose()
|
virtual |
Gets the sensor's pose estimate at a specific timestamp.
Queries the sensor for its pose estimate at the given timestamp. This is typically used for sensors that provide visual-inertial odometry or other pose estimation capabilities.
- Parameters
-
stamp Timestamp in seconds for which to query the pose [out] pose Output transform representing the sensor pose [out] covariance Output covariance matrix (6x6) representing twist uncertainty maxWaitTime Maximum time in seconds to wait for pose data (default: 0.06)
- Returns
- True if pose was successfully retrieved, false otherwise
- Note
- Default implementation returns false. Derived classes should override if they support pose estimation.
- See also
- odomProvided()
Reimplemented from rtabmap::SensorCapture.
◆ driver()
|
inline |
Definition at line 93 of file DBReader.h.
◆ captureImage()
|
protectedvirtual |
Implements rtabmap::Camera.
The documentation for this class was generated from the following file:
- corelib/include/rtabmap/core/DBReader.h