|
|
| RegistrationVis (const ParametersMap ¶meters=ParametersMap(), Registration *child=0) |
| | child is owned and deleted in the destructor.
|
| |
| virtual void | parseParameters (const ParametersMap ¶meters) |
| | Parses Vis/ and feature parameters; recreates feature detectors.
|
| |
| float | getInlierDistance () const |
| |
| int | getIterations () const |
| |
| int | getMinInliers () const |
| |
| int | getNNType () const |
| |
| float | getNNDR () const |
| |
| int | getEstimationType () const |
| |
| const Feature2D * | getDetector () const |
| |
|
bool | isImageRequired () const |
| | True if images are needed (parent or child).
|
| |
|
bool | isScanRequired () const |
| | True if laser scans are needed (parent or child).
|
| |
|
bool | isUserDataRequired () const |
| | True if user data is needed (parent or child).
|
| |
|
bool | canUseGuess () const |
| | True if the strategy can refine an initial guess (parent or child).
|
| |
|
int | getMinVisualCorrespondences () const |
| | Minimum visual inliers required (max of parent and child thresholds).
|
| |
|
float | getMinGeometryCorrespondencesRatio () const |
| | Minimum geometry inlier ratio required (max of parent and child thresholds).
|
| |
| bool | repeatOnce () const |
| |
| bool | force3DoF () const |
| |
|
void | setChildRegistration (Registration *child) |
| | Replaces child_; takes ownership of child.
|
| |
|
Transform | computeTransformation (const Signature &from, const Signature &to, Transform guess=Transform::getIdentity(), RegistrationInfo *info=0) const |
| | Registers from to to using immutable signatures (copied internally).
|
| |
|
Transform | computeTransformation (const SensorData &from, const SensorData &to, Transform guess=Transform::getIdentity(), RegistrationInfo *info=0) const |
| | Registers two SensorData observations (wrapped as signatures).
|
| |
|
Transform | computeTransformationMod (Signature &from, Signature &to, Transform guess=Transform::getIdentity(), RegistrationInfo *info=0) const |
| | Registers from to to; signatures may be modified by the implementation.
|
| |
|
| enum | Type { kTypeUndef = -1
, kTypeVis = 0
, kTypeIcp = 1
, kTypeVisIcp = 2
} |
| | Registration strategy selected by Reg/Strategy. More...
|
| |
|
static Registration * | create (const ParametersMap ¶meters) |
| | Creates a registration from Reg/Strategy in parameters. Caller owns the pointer.
|
| |
|
static Registration * | create (Type &type, const ParametersMap ¶meters=ParametersMap()) |
| | Creates a registration of type (may be adjusted, e.g. to kTypeVis). Caller owns the pointer.
|
| |
| static double | COVARIANCE_LINEAR_EPSILON |
| | Minimum diagonal value for linear covariance (m²).
|
| |
| static double | COVARIANCE_ANGULAR_EPSILON |
| | Minimum diagonal value for angular covariance (rad²).
|
| |
Visual registration between two signatures using features and geometry.
Extracts and matches features (Feature2D), then estimates motion with Vis/EstimationType (3D→3D, 3D→2D PnP, or 2D→2D epipolar). Supports RGB-D (CameraModel + depth), stereo (StereoCameraModel), optical flow, GMS, and optional Python matchers when built with Python support.
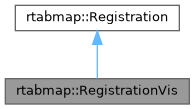
Can chain a child_ registration (e.g. RegistrationIcp in Registration::kTypeVisIcp). Feature-related Vis/ parameters are mapped to Kp/ for Feature2D::create().
- See also
- Registration
-
RegistrationInfo
Definition at line 60 of file RegistrationVis.h.

 Public Member Functions inherited from rtabmap::Registration