diff --git a/Robust-Graph-Optimization.md b/Robust-Graph-Optimization.md
index 2cab26e..8c4553f 100644
--- a/Robust-Graph-Optimization.md
+++ b/Robust-Graph-Optimization.md
@@ -6,8 +6,12 @@ Even if RTAB-Map has a [good](https://introlab.3it.usherbrooke.ca/mediawiki-intr
 +[1] Latif Y, Cadena C and Neira J (2013) Robust loop closing over time for pose graph slam. Int. J. of Robotics Research 32(14): 1611—1626.
+
+[2] Sunderhauf N and Protzel P (2012) Towards a robust back-end for pose graph SLAM. In: Proc. IEEE Int. Conf. on Robotics and Automation. pp. 1254–1261.
+
## Configuration
-In the Preferences dialog under RGBD-SLAM panel and "Graph optimization" group, choose either g2o or GTSAM for the optimization algorithm, then click on "Robust graph optimization with Vertigo..." (default already checked):
+In the Preferences dialog under RGBD-SLAM panel and "Graph optimization" group, choose either g2o or GTSAM for the optimization algorithm, then click on "Robust graph optimization using Vertigo..." (default already checked):
### ROS
If you are using ROS, you can set the parameters of the rtabmap node like that in a launch file:
@@ -20,13 +24,14 @@ If you are using ROS, you can set the parameters of the rtabmap node like that i
```
## Example
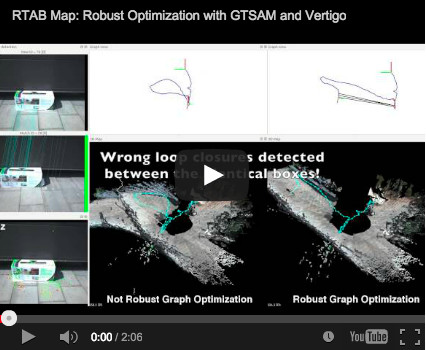
-The video above can be reproduced with this database: stereo_robust_optimization.db (xx MB).
+The video above can be reproduced with this database: [robust_graph_optimization_stereo.db](https://raw.githubusercontent.com/wiki/introlab/rtabmap/doc/Tutorials/RobustGraphOptimization/robust_graph_optimization_stereo.db) (32 MB).
1. Open RTAB-Map.
2. Open Preferences dialog.
3. Restore default settings (Preferences->General Settings->"Reset all settings").
4. Click on Source panel: set source from database, scroll down and select the database above and click on "Yes" to use odometry saved in database.
- 5. Click on Advanced (bottom left) to show up the RGB-D SLAM panel, then click on it. Set the panel as in the screenshot of the previous section (with g2o or GTSAM).
+ 5. Click on RTAB-Map settings: set "Detection rate" to 0. The source database is already at 1 Hz, it is just to make sure that all images are processed.
+5. Click on Advanced (bottom left) to show up the RGB-D SLAM panel, then click on it. Set the panel as in the screenshot of the previous section (with g2o or GTSAM).
6. Close the Preferences dialog.
7. Create a new database (File -> New database) and click "Start".